Nick Popelnukh

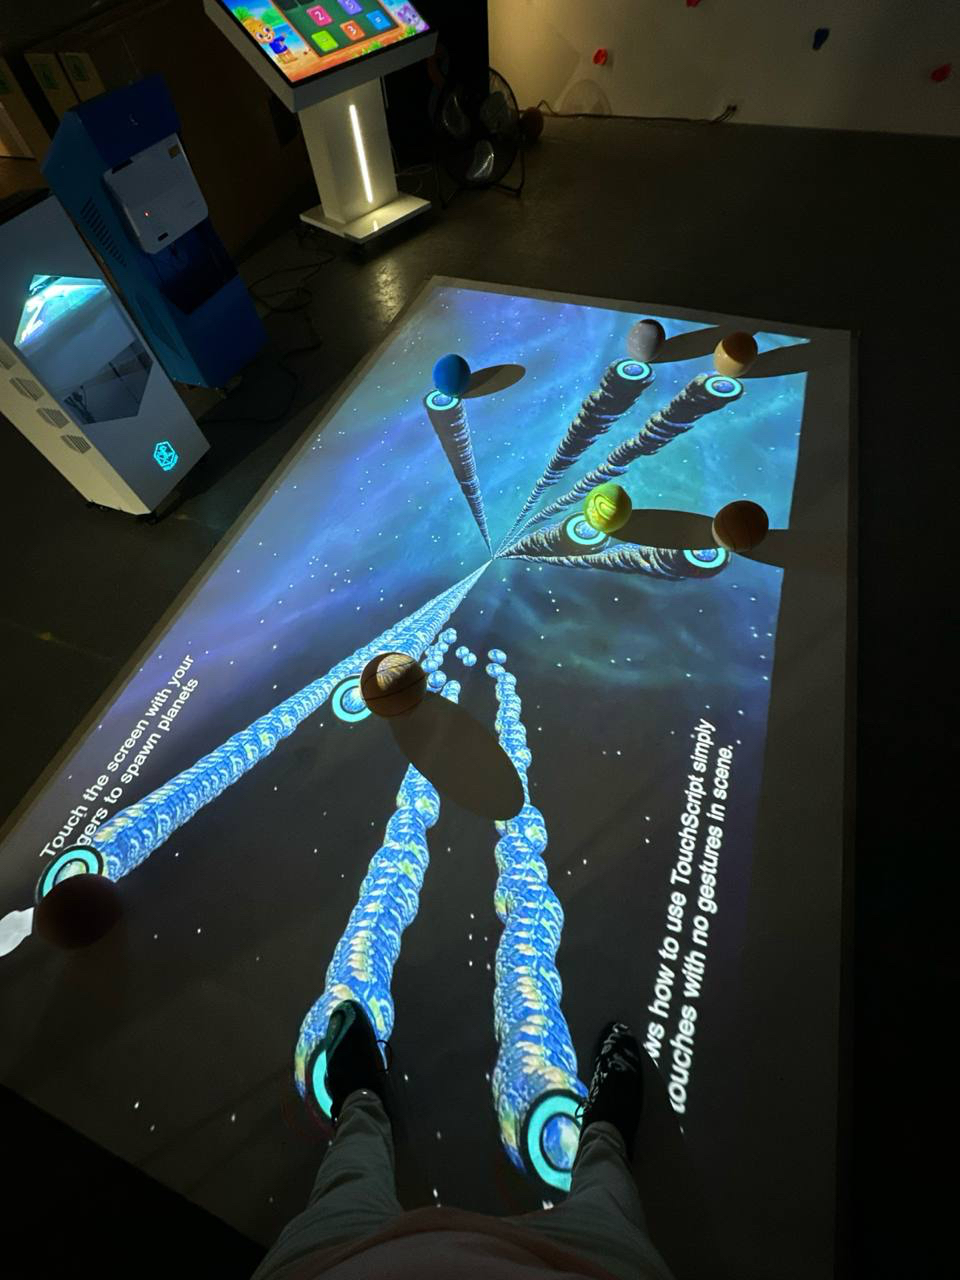
I'm a machine learning engineer in Toronto working on real-time computer vision. For the last three years I built the perception models that run inside 3,000+ interactive projection systems, covering 3D body tracking, hand tracking, and the calibration software used to set them up.

My work focuses on making models fast and robust enough to run live on-device: fusing depth with RGB, handling low light, and exporting to TensorRT. I've also built LLM-powered automation (RAG) in production. I'm admitted to the M.Sc. in Computer Science at Georgia Tech, and I'm interested in turning this applied work into research.

Nick Popelnukh

Projects

Work at Kids Jump Tech, shipped to production hardware.

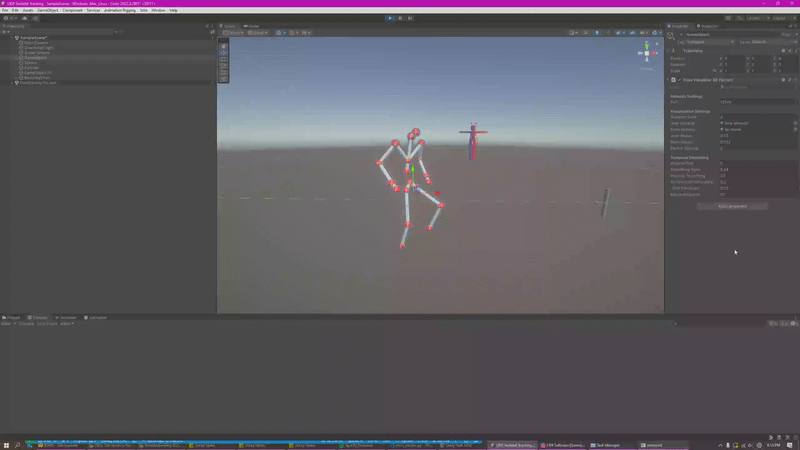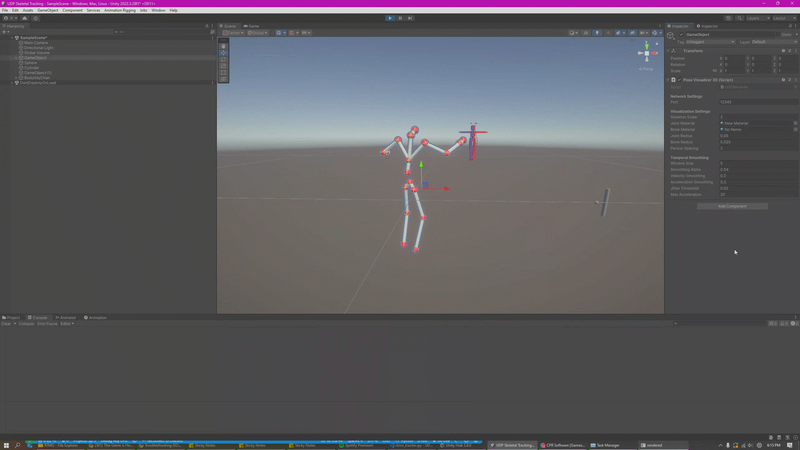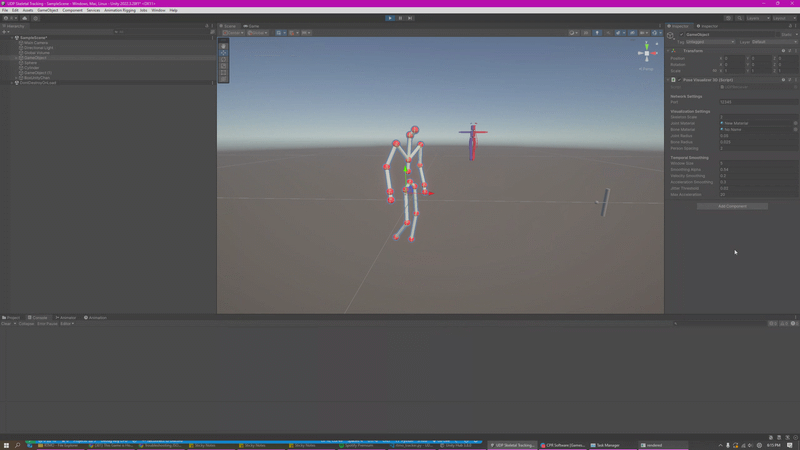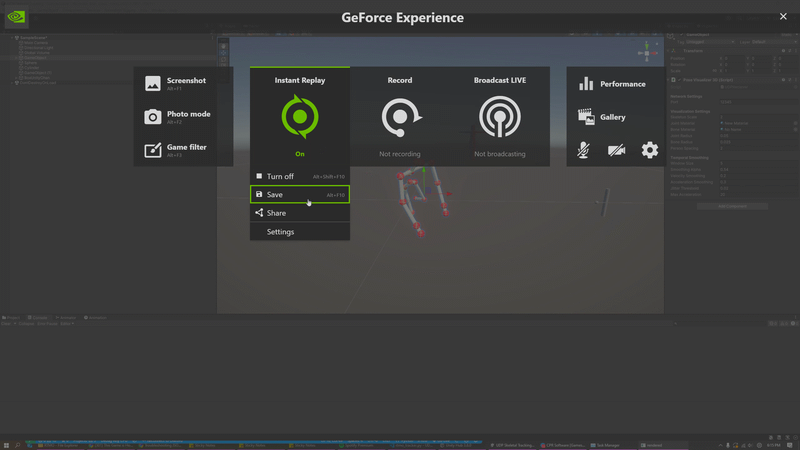
Diagram: RGB and depth frames fused into a 3D body skeleton at about 70 FPS
Real-time 3D body tracking with depth fusion PyTorch, ROMP, Intel RealSense, AWS SageMaker

Extended ROMP with a depth branch that fuses RealSense depth and RGB features. Runs at ~70 FPS and shipped to 3,000+ hardware units on low-profile RTX 5050 GPUs.

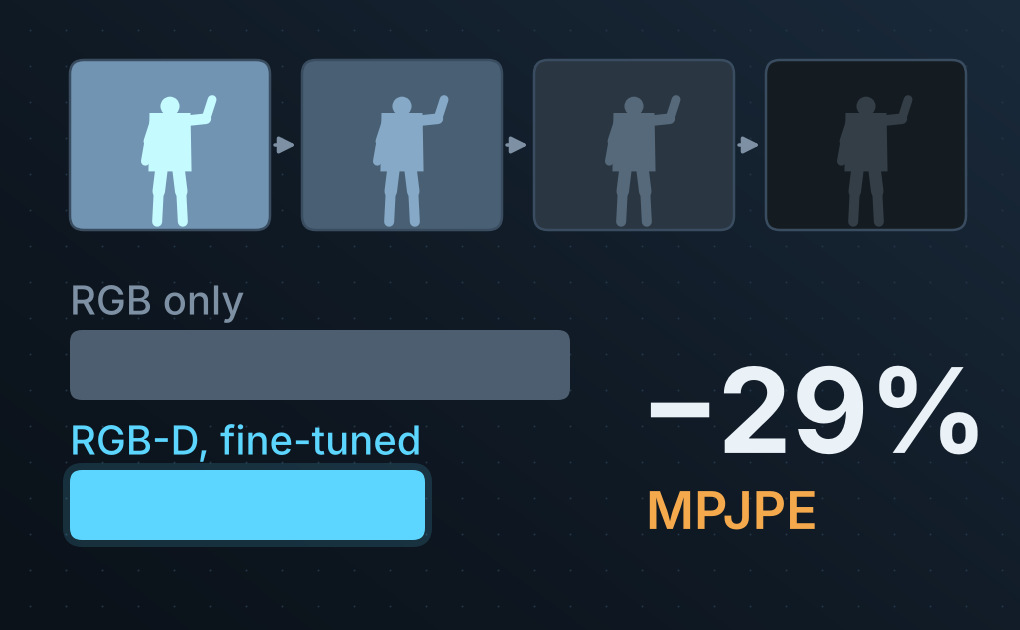
Diagram: progressively darkened frames and a 29% lower MPJPE bar for the RGB-D model versus RGB-only
Low-light 3D pose estimation from synthetic darkening SMPL fitting, RGB-D, MPJPE

Fine-tuned on ~40K self-generated, synthetically darkened RGB-D frames with SMPL fitting. Cut low-light pose error by ~29% (MPJPE) relative to an RGB-only baseline.

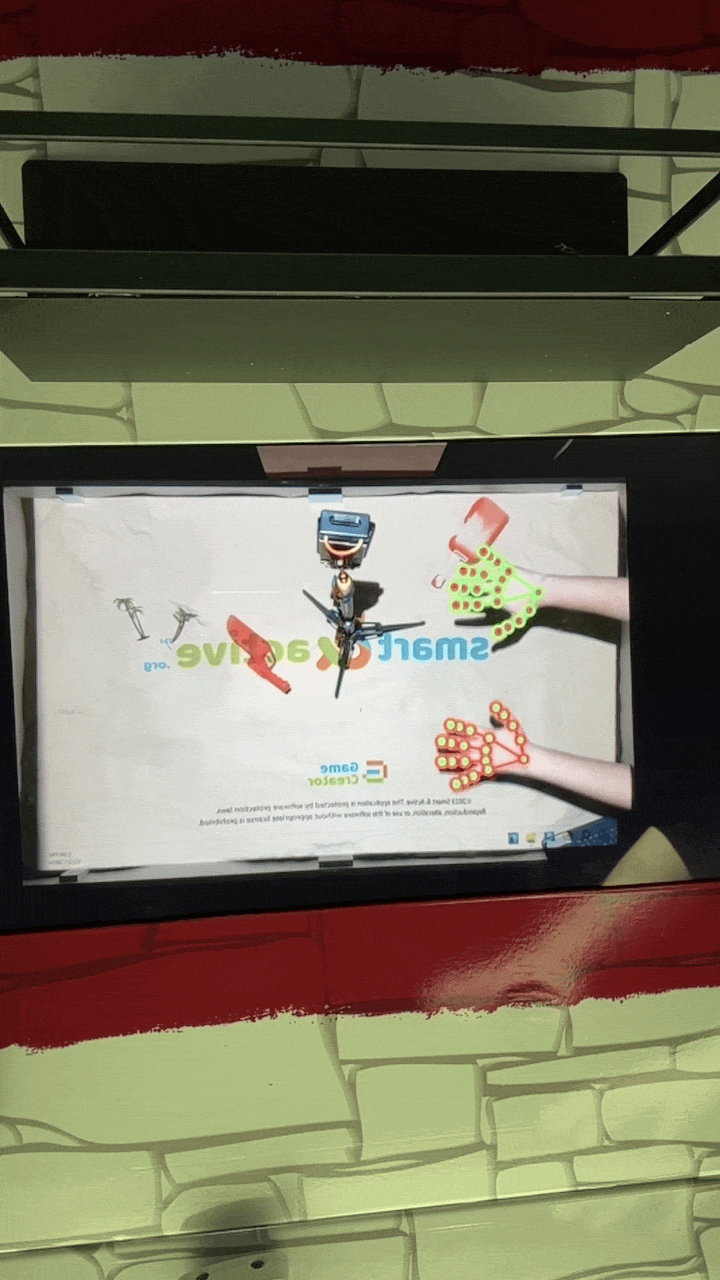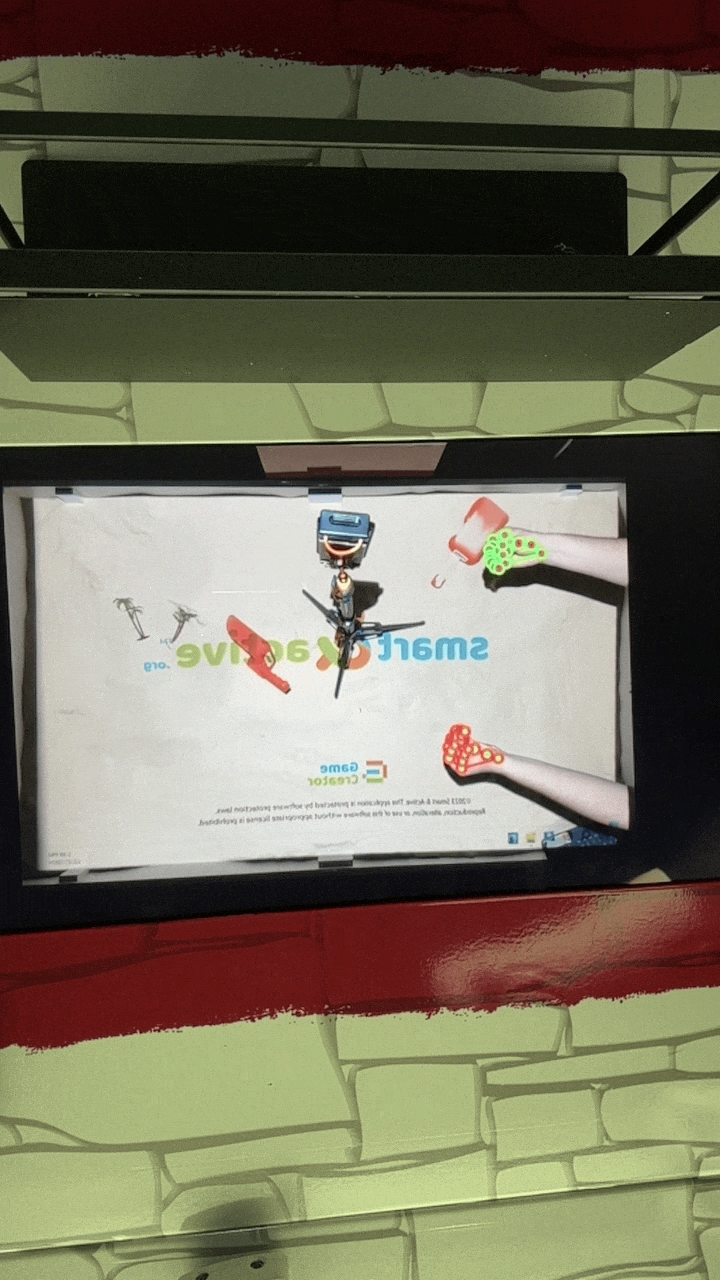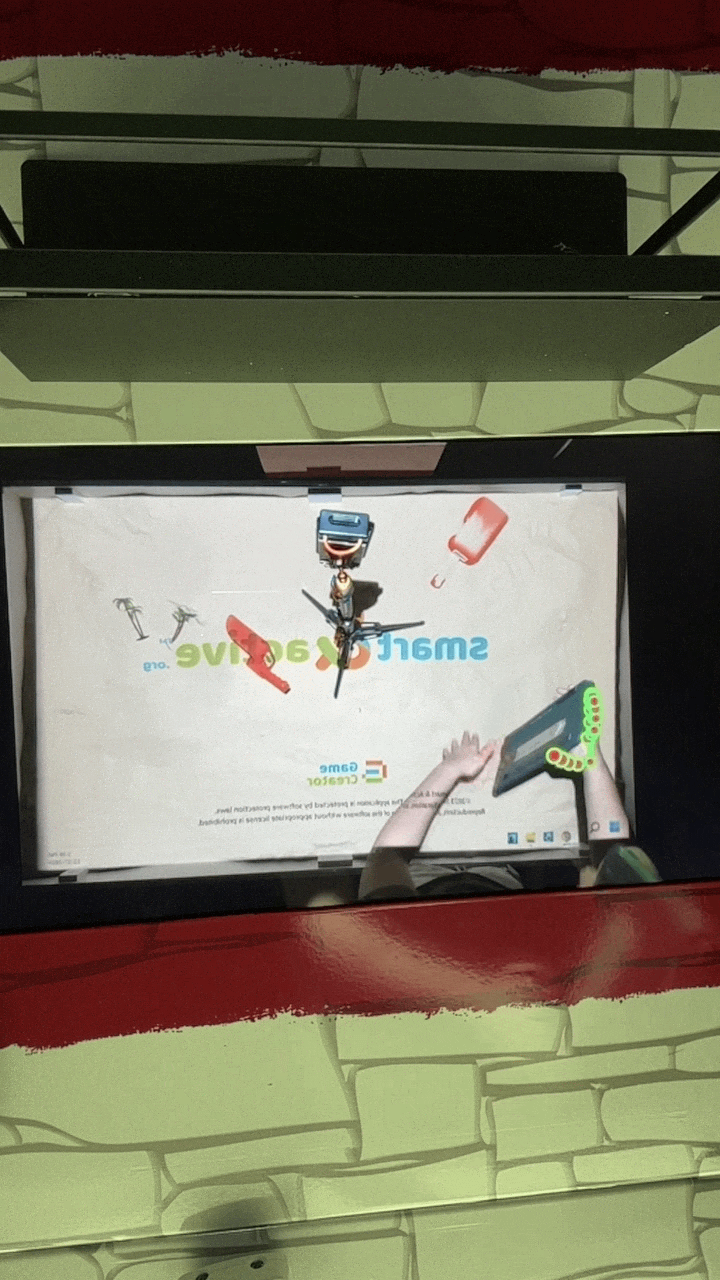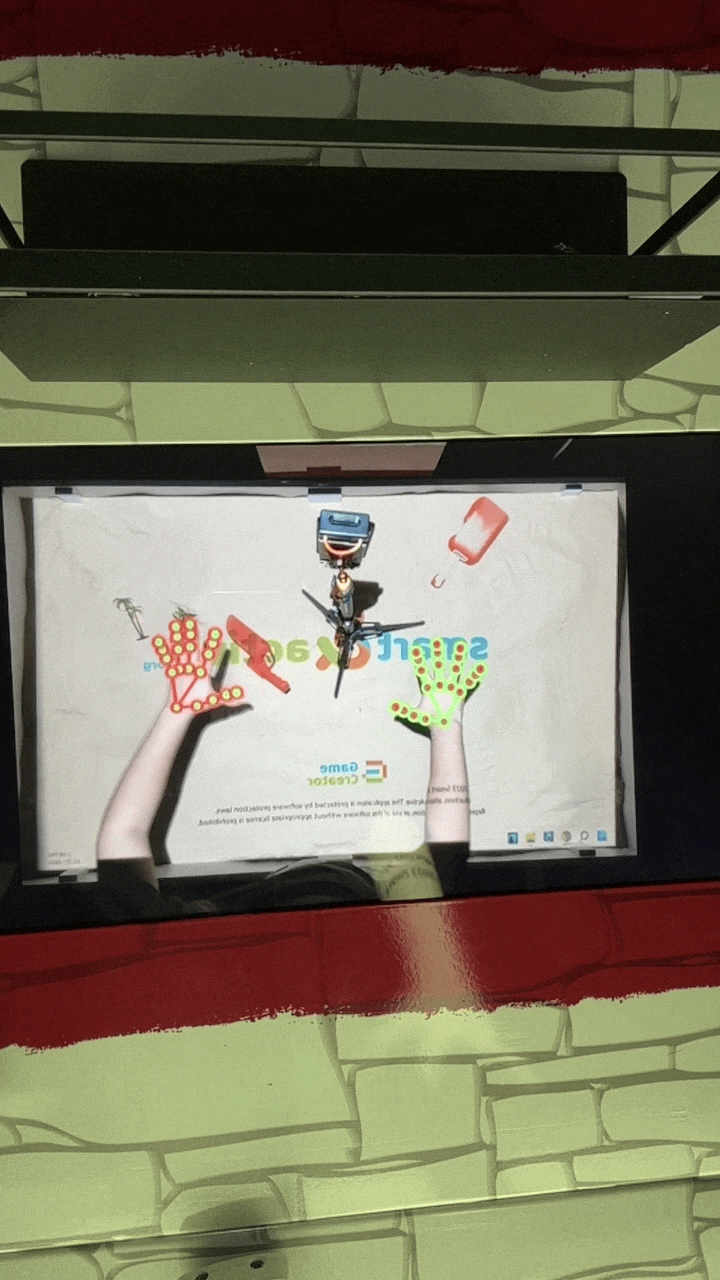
Hand-joint skeleton with 10 mm versus 15 mm low-light error bars
Depth-fused hand tracking for custom gestures RTMPose, knowledge distillation, RGB-D

Distilled a student model from RTMPose that fuses depth with darkened RGB. In low light it reaches 10 mm root-relative joint error versus 15 mm for RGB-only (~33% lower) at ~30 ms. Because it tracks joints instead of classifying fixed gestures, users can define unlimited gestures.

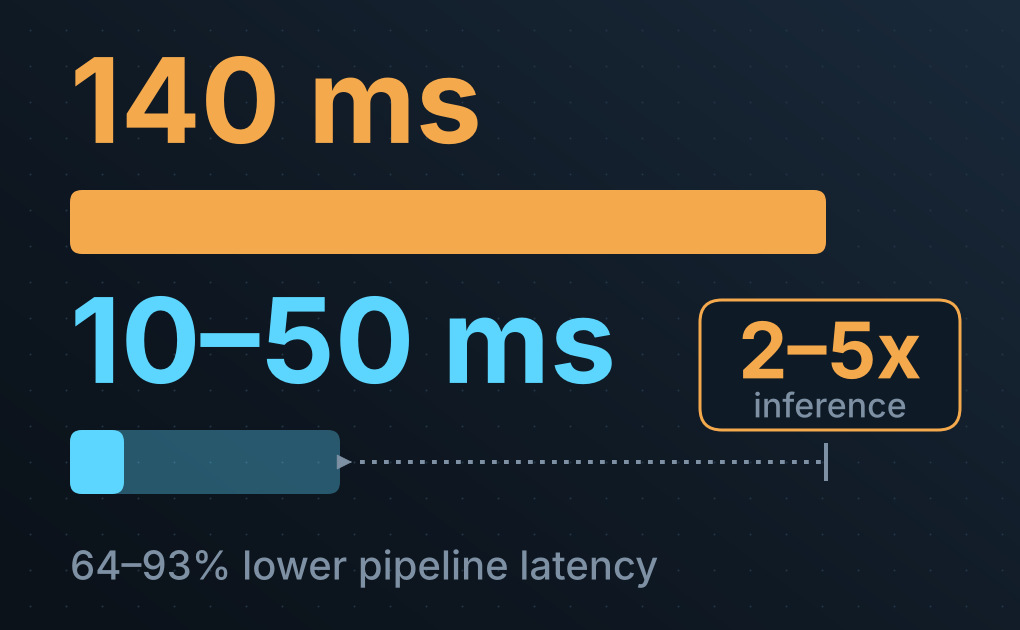
Bar chart: sensor pipeline latency reduced from 140 ms to 10 to 50 ms
Inference and pipeline optimization ONNX, TensorRT, FP16, C++, C#, Python

Sped up model inference 2–5x with FP16 TensorRT exports and no visible accuracy regression in visual QA. Profiled and optimized the sensor pipeline, cutting latency 64–93% (140 ms down to 10–50 ms).

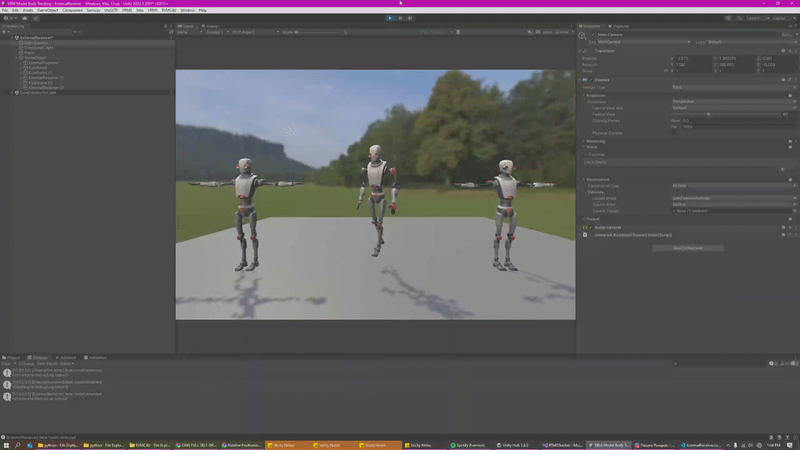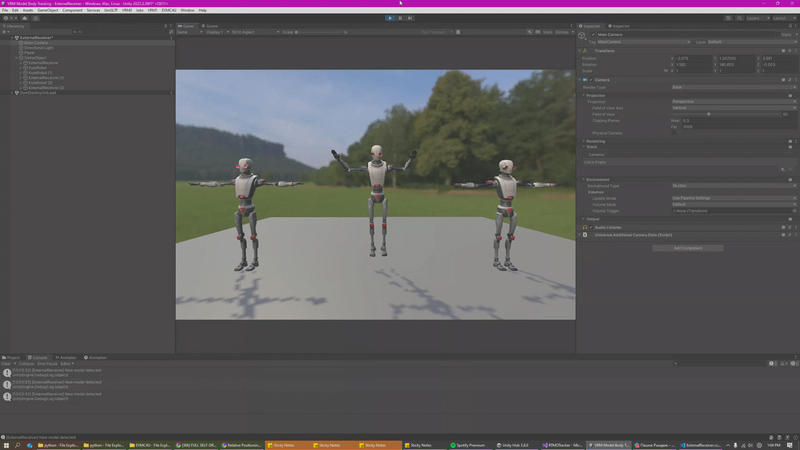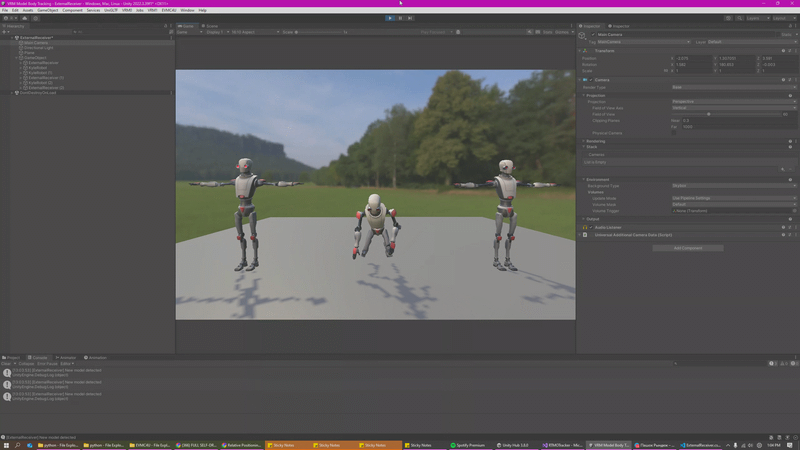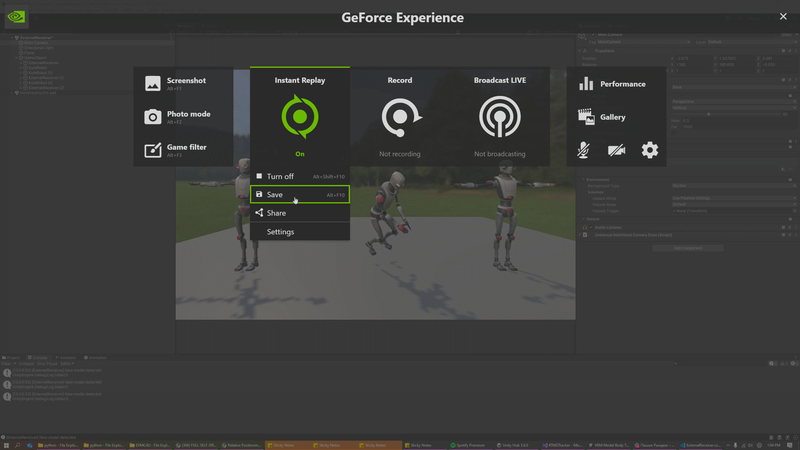
A human skeleton retargeted onto several different character rigs
Live human-to-character motion capture and LiDAR touch Unity, Python, LiDAR

Built the company's first live motion capture feature, retargeting tracked human motion onto any T-pose rig (20+ rigs). Also built the pipeline that turns LiDAR wall and floor touches into Unity touch events.

Diagram of a sensor, projector and floor plane aligned for projection mapping
In-house sensor and projection calibration Extrinsics, floor-plane alignment, projection mapping

Replaced a deprecated third-party tool with software for sensor extrinsics alignment, floor-plane alignment, and display/projection mapping. It is used in customer setup and saves an estimated ~$600K/year in licensing.

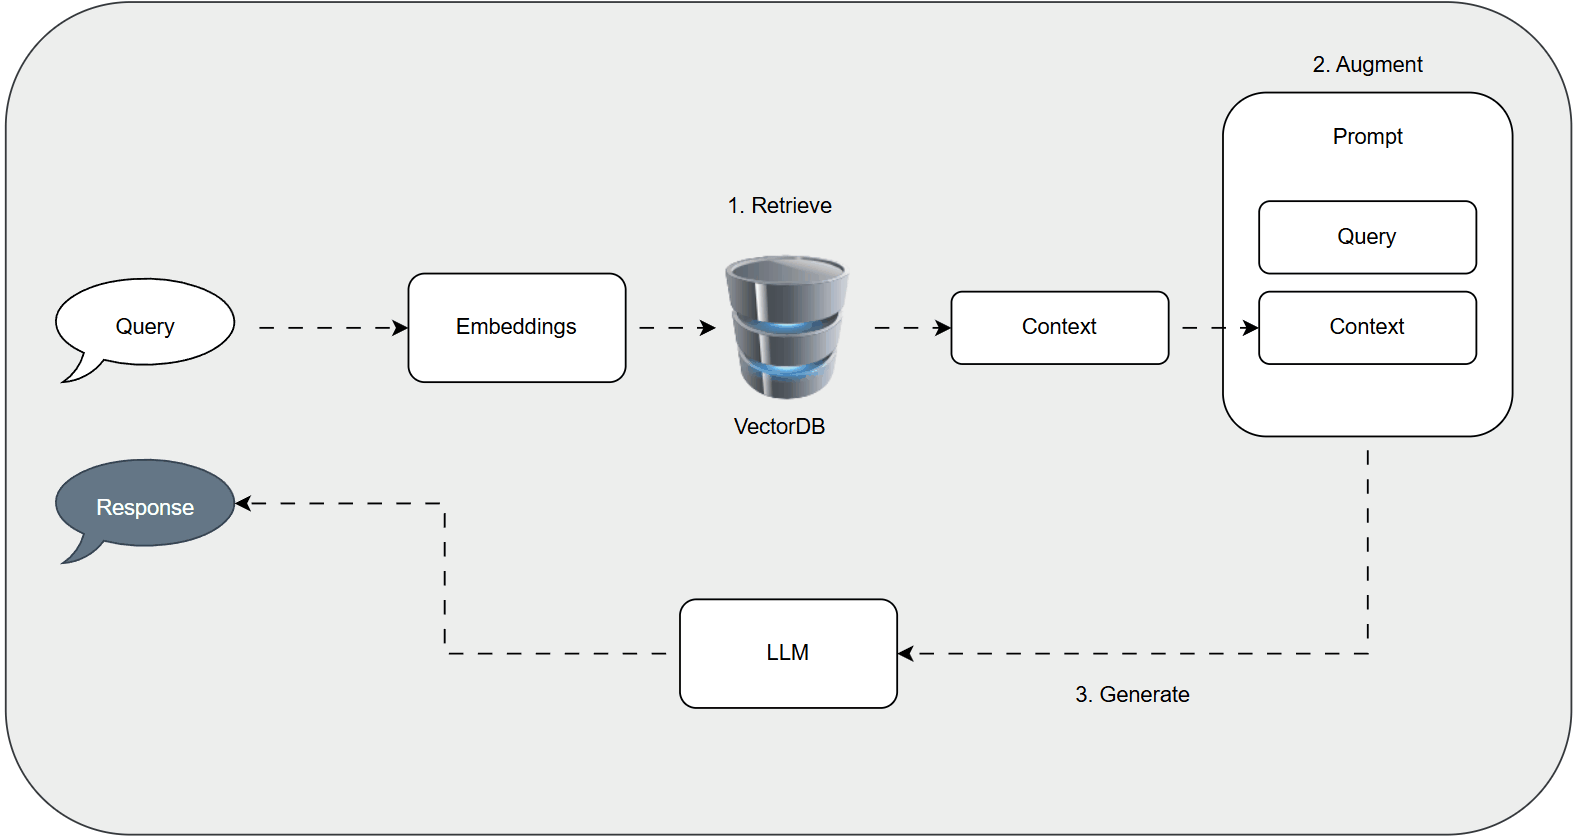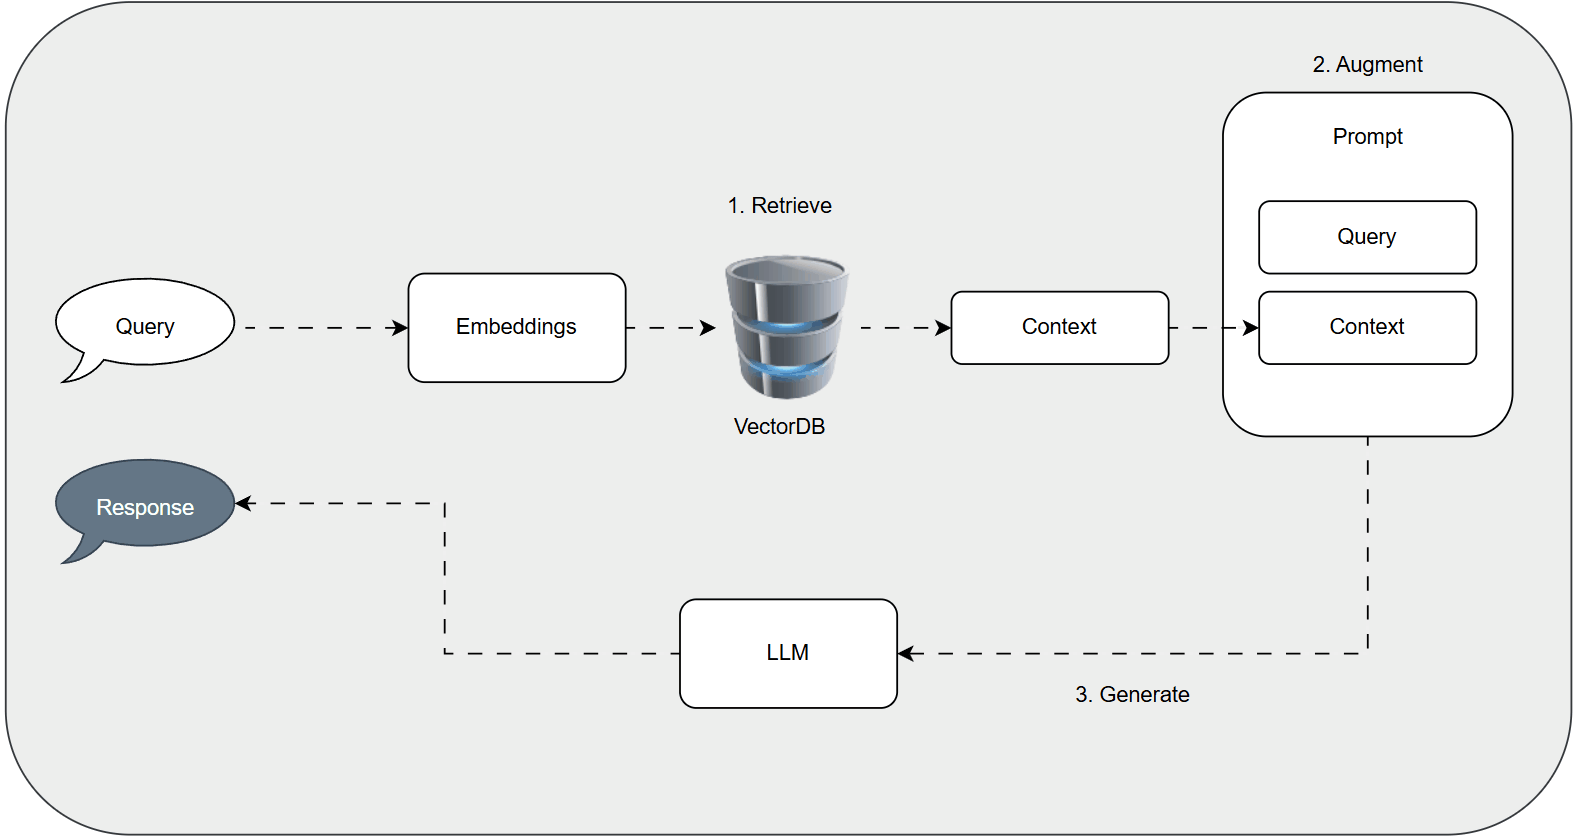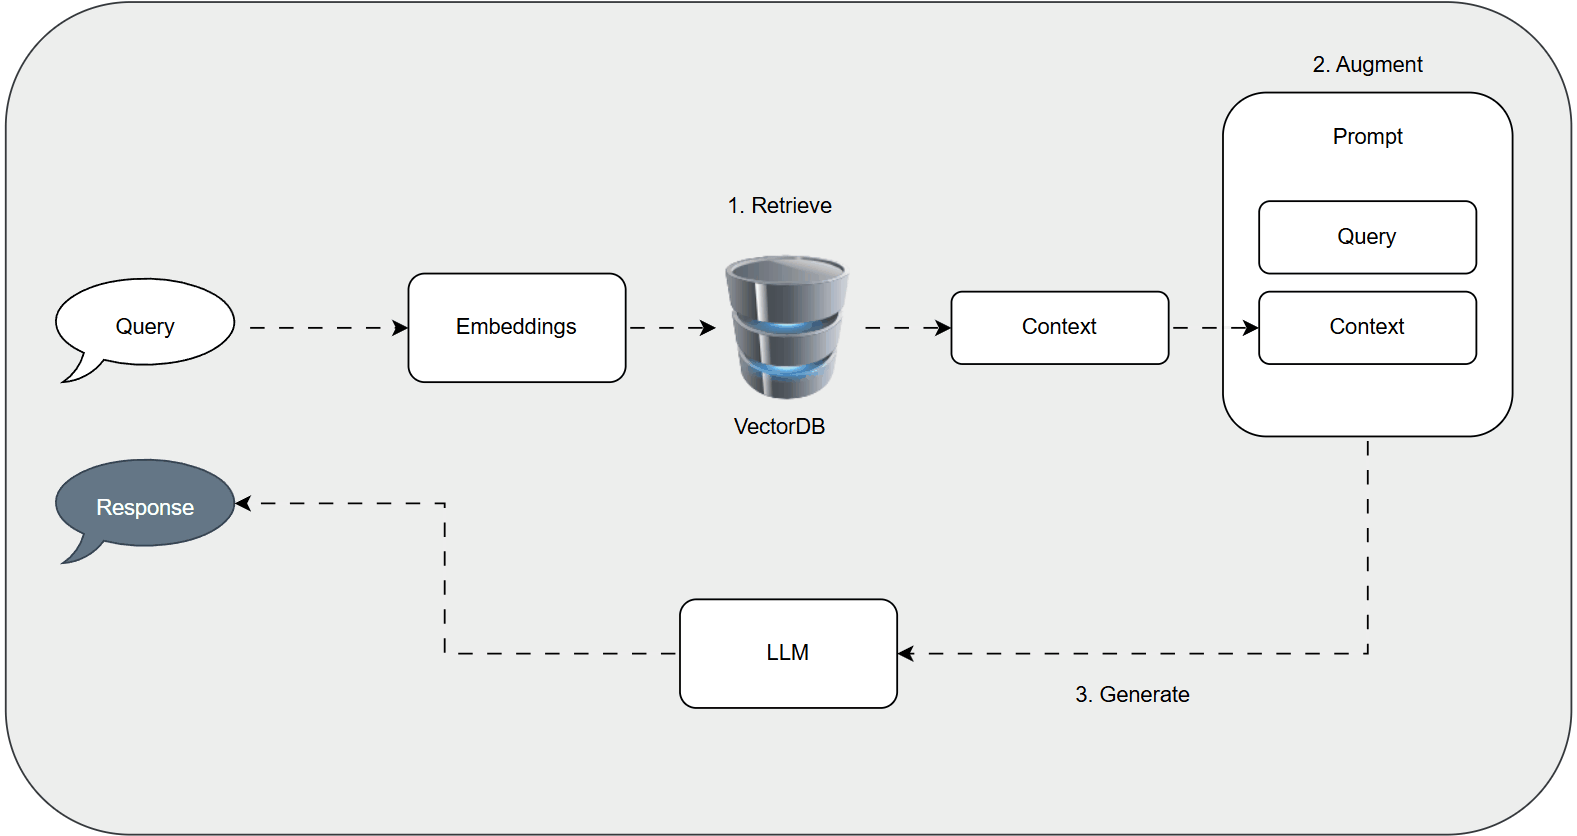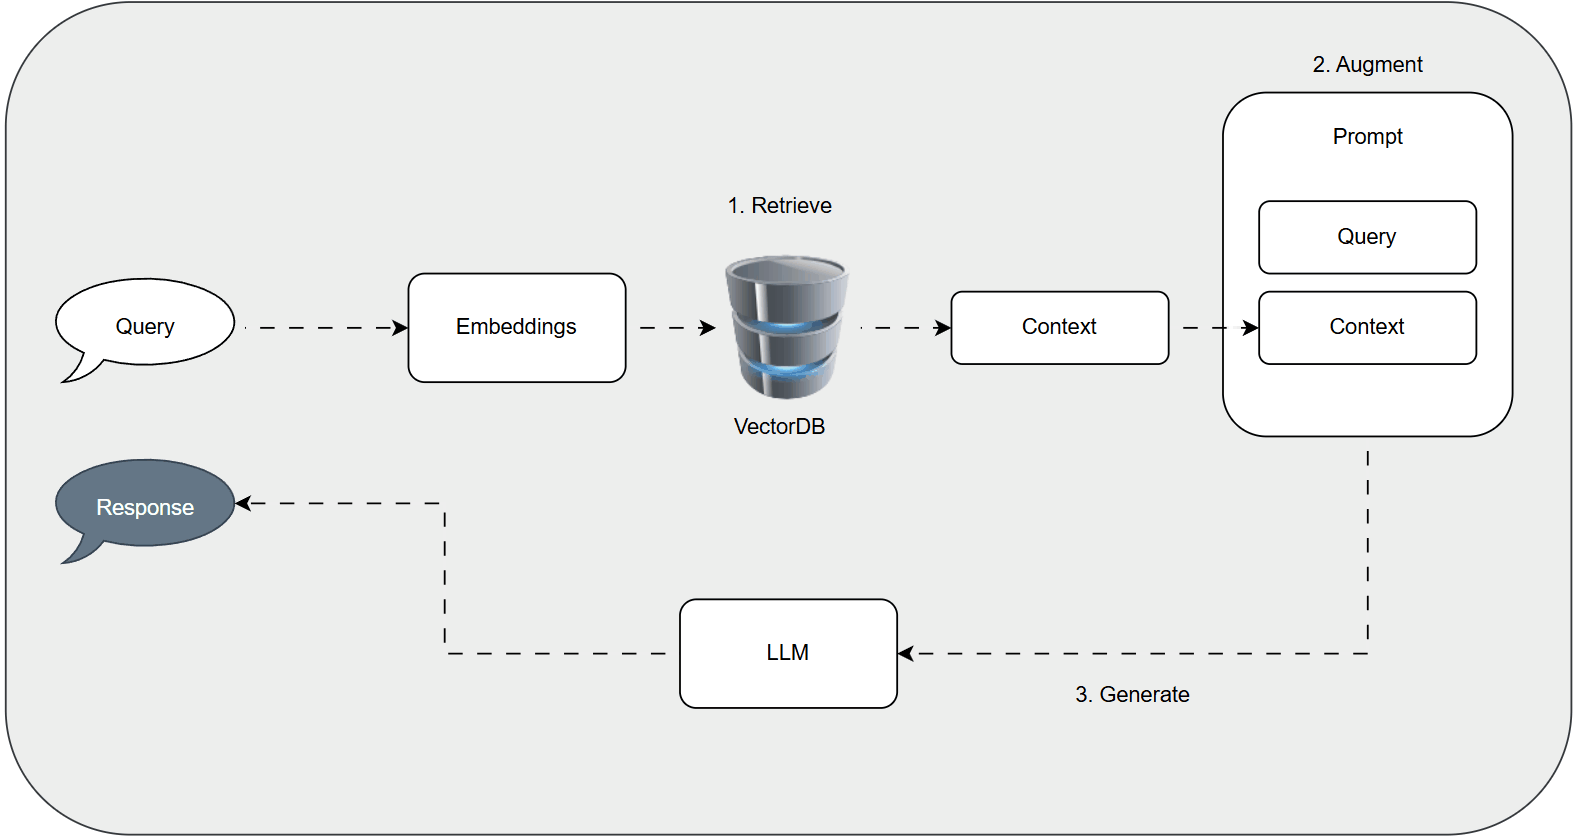
Pipeline diagram: documents to vector index to LLM to marketplace listing
LLM-powered marketplace automation RAG, OpenSearch, PostgreSQL, Next.js

At Classeasily, built a RAG pipeline and LLM automation that keeps marketplace listings current and analyzes customer reviews, running in production. Also cut search latency 92–94% (~5 s to ~0.3–0.4 s) by moving from SQL joins to OpenSearch.

Experience

Nov 2023 – Oct 2026
Machine Learning Engineer, Kids Jump Tech
Interactive floor, wall, and table systems for schools and entertainment venues. Miami, FL (hybrid)
Jan 2025 – Aug 2026
Founding Lead Engineer (part-time), Classeasily
Marketplace platform reaching 20,000+ people, built with a team of 6. Toronto, ON (remote)
Aug 2025 – Oct 2026
Software Engineer (part-time), Confident Care of Florida
Event-driven AWS Lambda automation and company website. Jacksonville, FL (hybrid)

Education

Admitted
M.Sc. in Computer Science, Georgia Institute of Technology
Jul 2020 – Oct 2023
B.Sc. in Computer Science, Western Governors University

Skills

Languages
Python, C++, C#, SQL, TypeScript
ML and real-time
PyTorch, TensorFlow/Keras, scikit-learn, OpenCV, CUDA, ONNX, TensorRT, FP16 quantization, ROMP, SMPL, RTMPose, YOLO, MediaPipe, Detectron, Intel RealSense, LiDAR
MLOps
AWS SageMaker, NVIDIA Jetson, MLflow, Weights & Biases, Docker, Kubernetes, Terraform, GitHub Actions
LLMs
Hugging Face Transformers, LoRA fine-tuning, RAG and vector databases, OpenAI and Anthropic APIs
Backend and web
Node.js, REST APIs, PostgreSQL, OpenSearch, AWS (Lambda, EKS, S3), React, Next.js